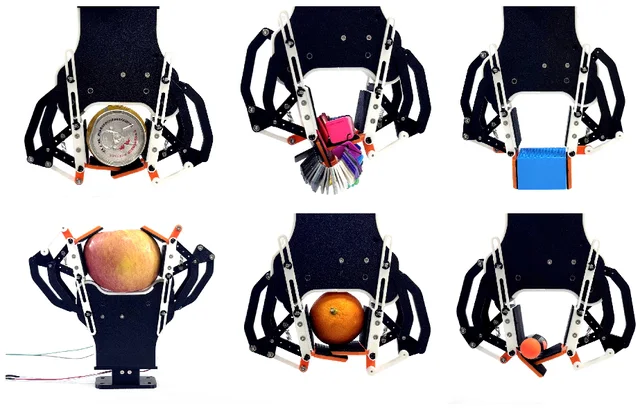
Selected publications
-
IROS 2025 · Oral
-
CASE 2025 · Oral 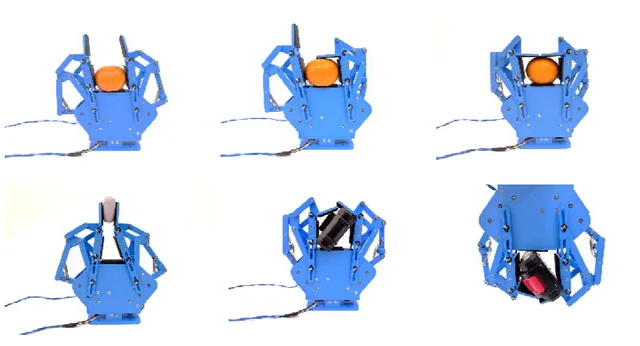
news
- "An Underactuated Gripper with Independent Double-Parallelogram Linkages" is now available on IEEE Xplore. Congrats Yizhe!
- Started a visiting appointment at the State Key Lab of Mechanical System and Vibration, Shanghai Jiao Tong University, with Prof. Wei Dong.
- Received the National Scholarship from the Ministry of Education of China.
- Won the Undergraduate Champion award at the ASME Student Mechanism & Robot Design Competition.
research
01 · underactuated grippers
Peaucellier linkages, idle-stroke mechanisms, and adaptive grasping strategies for dexterous manipulation with minimal actuators.
02 · aerial manipulation
UAV perching mechanisms with electromagnetic adhesion systems for stable attachment and manipulation on varied surfaces.
projects
01 · semi-peaucellier gripper
An underactuated gripper that integrates an optimized Peaucellier linkage with idle-stroke transmission, achieving linear parallel pinching and shape-adaptive enveloping under a single motor.
02 · GLINT in-hand manipulation
A grasp-and-lift hand that embeds phase switching directly into a lost-motion transmission, separating force-free alignment from force-transmitting lifting and offloading control burden onto the mechanism.
03 · aerial manipulation @ SJTU
During my SJTU visit, I worked with Prof. Wei Dong on UAV perching and contact-rich aerial manipulation, exploring how mechanism-level designs translate to flying platforms.
education

Mohamed bin Zayed University of Artificial Intelligence
M.Sc. in Robotics
2026.08–present
Tsinghua University Tsien Excellence in Engineering Program · Shenzhen X-Institute
X Scholar in a joint training program focused on underactuated robotic grippers and linkage design.
2023.09–2026.09
Shenzhen Technology University
B.Eng. in Electronic Science and Technology, Future Technology School
2022.09–2026.07
experience
Visiting Student · State Key Laboratory of Mechanical System and Vibration, Shanghai Jiao Tong University
Worked with Prof. Wei Dong on UAV perching and aerial manipulation, including controllers and mechanism designs for contact-rich UAV tasks.
2026.02–2026.08
service
- Conference reviewer for IEEE/RSJ IROS and IEEE CASE.
- Conference session chair for IEEE/RSJ IROS 2025.
awards
selected honors
- 2026Top 10 Outstanding Graduate, Shenzhen Technology Universityuniversity
- 2025National Scholarshipnational
- 2025Undergraduate Champion, ASME Student Mechanism & Robot Design Competitioninternational
- 2024President's Award, Shenzhen Technology Universityuniversity
- 2023Gold Prize, 9th China “Internet+” Innovation Competition (Guangdong Division)provincial
- 2023Second Prize, 17th “Challenge Cup” Extracurricular Science Competition (Guangdong Division)provincial
availability
Busy-only calendar for planning a meeting.
My Free/Busy Hours (Asia/Dubai time)
Calendar data loads when opened.